所屬科目:中山◆電機◆控制系統
2. Design a feedback controller to regulate the output of the plantto any prescribed constant level without any steady-state error, and make the resulting closed-loop polesat s =-70,-100.
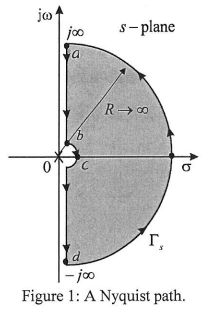
(a) A Nyquist path is shown in Fig. 1.Sketch the Nyquist plot of this system for K >0 in accordance with fig. 1, and indicate clearly I. theintersection(s) of the Nyquist plot with real and imaginary axes if any II. each mapping of pointa:(0+jω,ω→∞⁺),6:(0+jω,ω→0⁺),c:(,φ→0⁺)and d:(0-jω,ω→∞⁺) in your
plot.
(b) Suppose that the Nyquist plot ( K >0) you obtained in part (a) is depicted in Fig. 2, where thesolid line is part of the Nyquist plot when ω is from ∞ ⁺ to 0⁺, and it has an intersection with axis-Re(L(s)) at -K.Using Nyquist criterion, determine the range of K > 0 such that the closed-loop system can be stabilized.If the system is unstable due to the range of K, find the number of closed-loop pole(s) in the right-half ofs-plane.
 阿摩線上測驗
登入
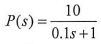
 ,φ→0⁺)and d:(0-jω,ω→∞⁺) in your
